Build sheet · 2024
Autonomous Surveillance Robot
I designed and built this robot from scratch. It patrols on its own, spots people in live video and sends an alert, with everything running on a Raspberry Pi on the robot itself.
- Python
- Raspberry Pi
- OpenCV
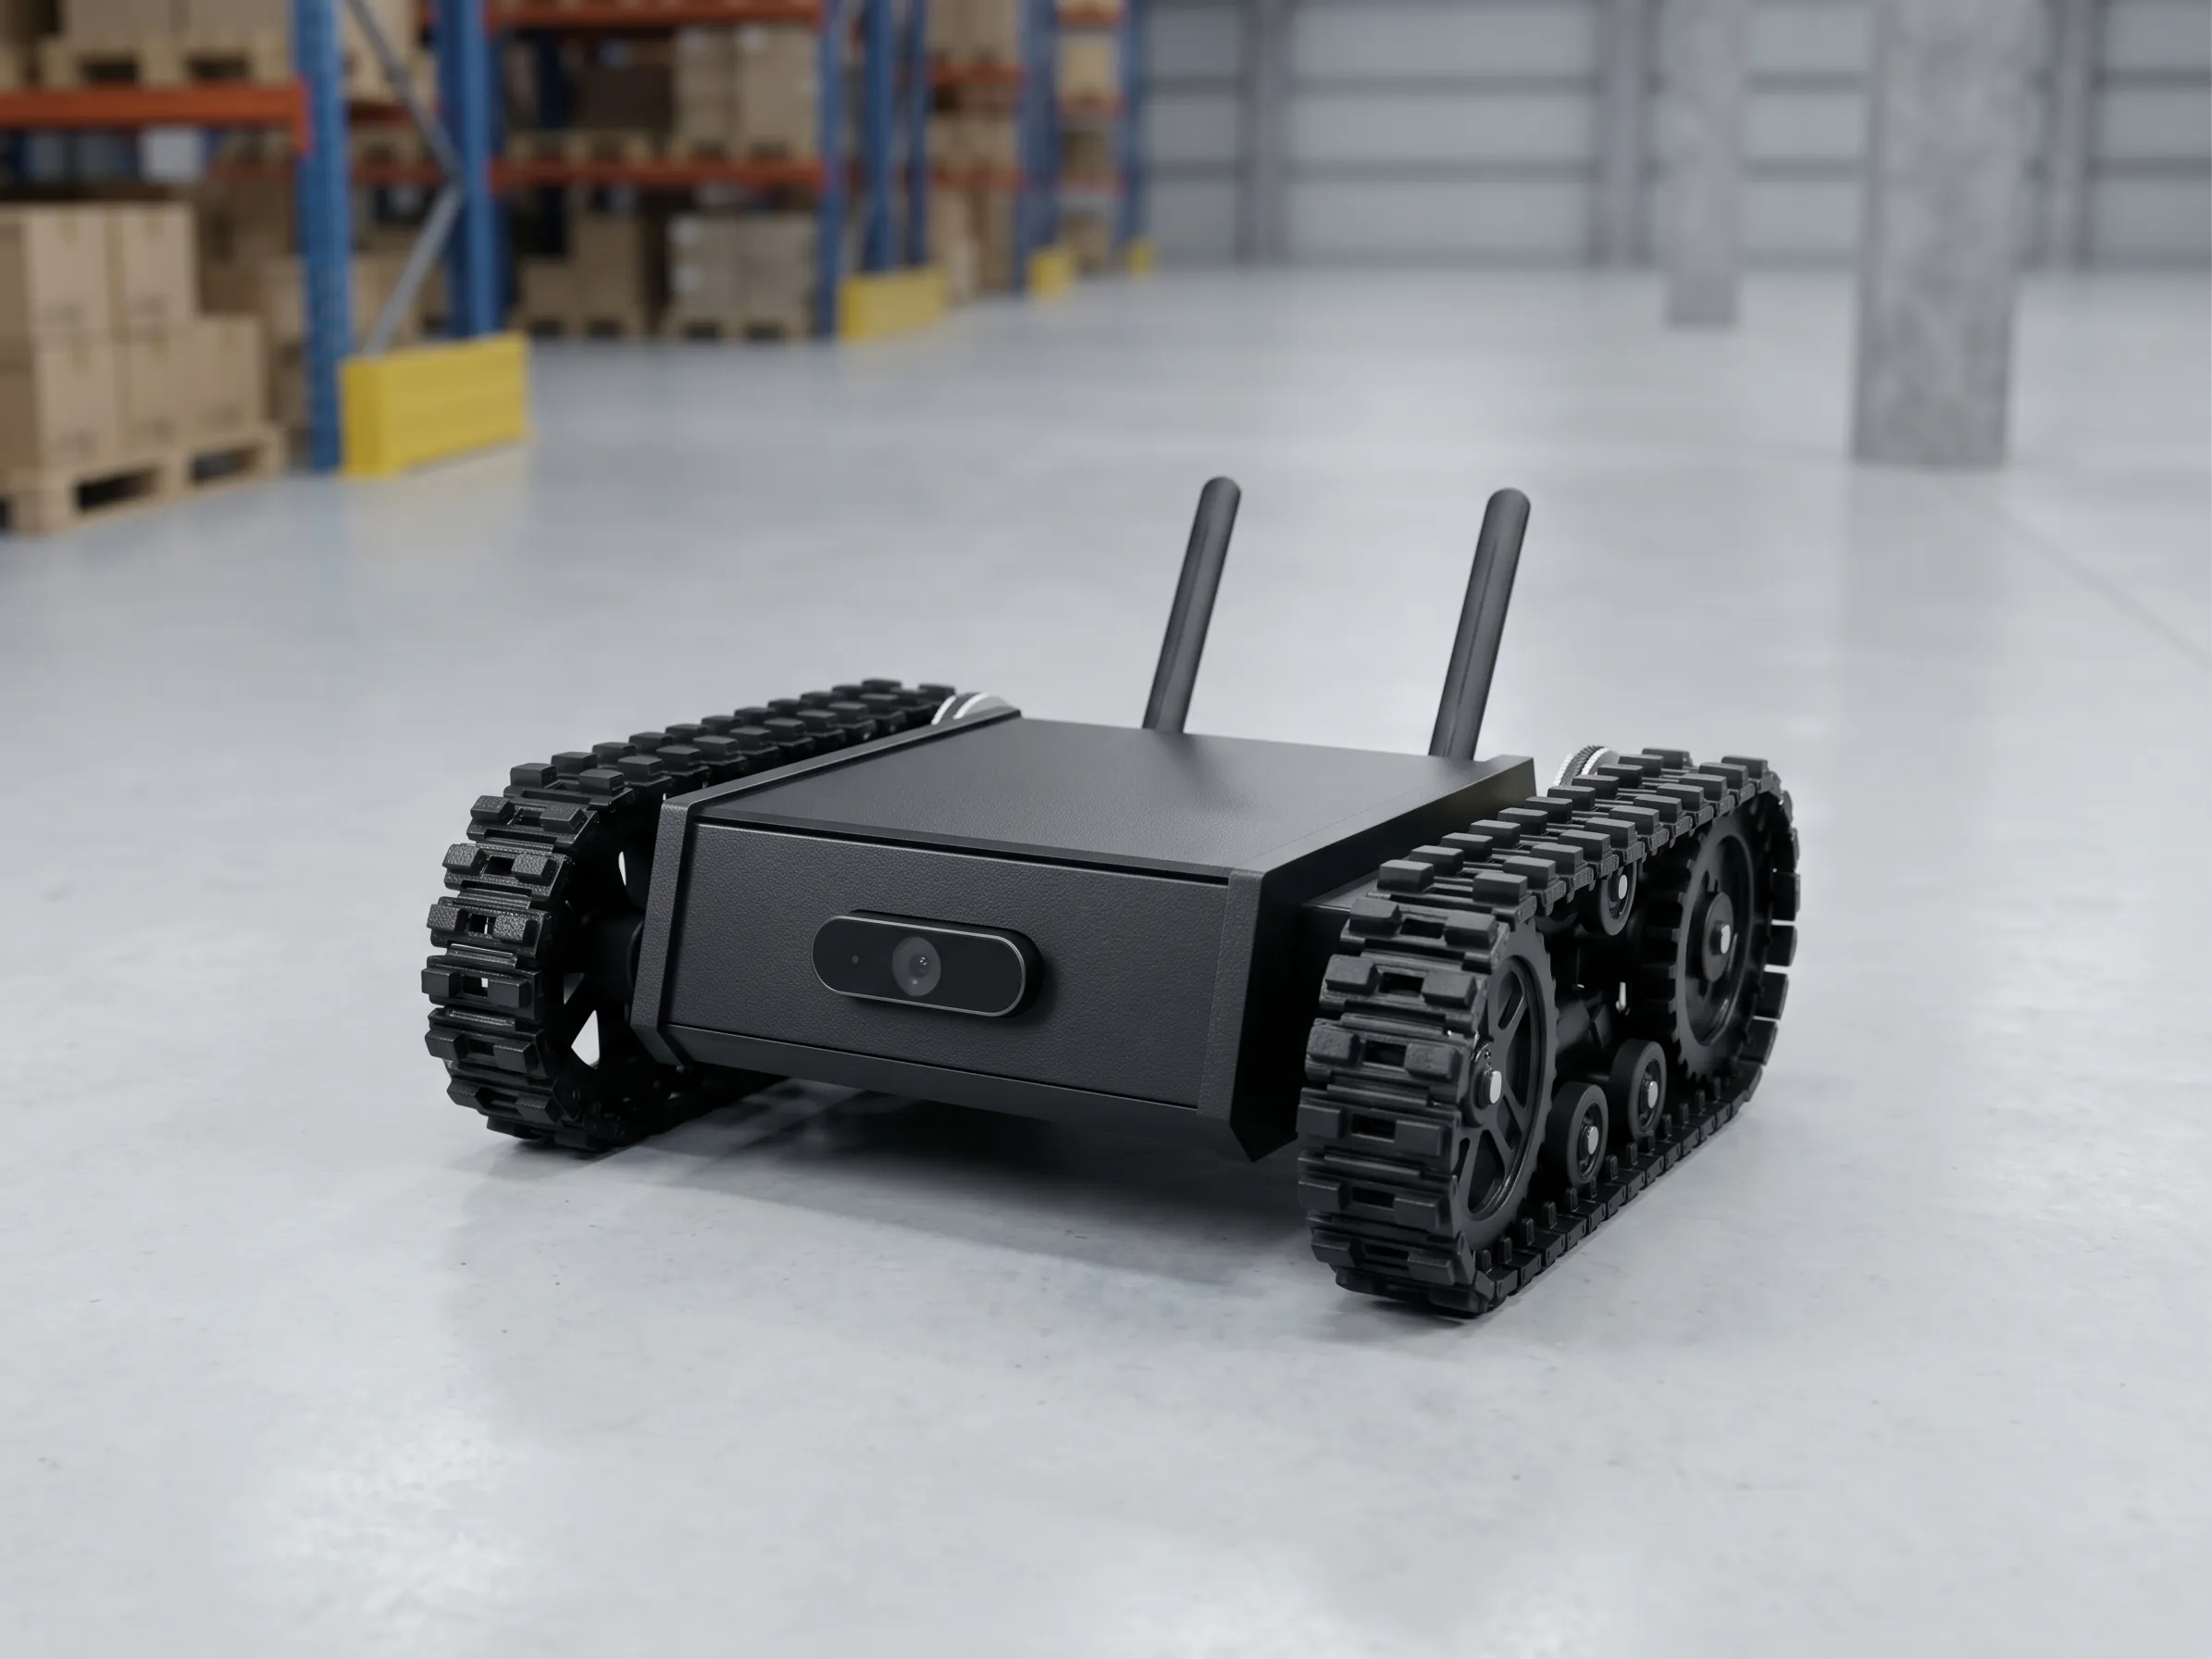
Fig. 2 · the real robot
The robot
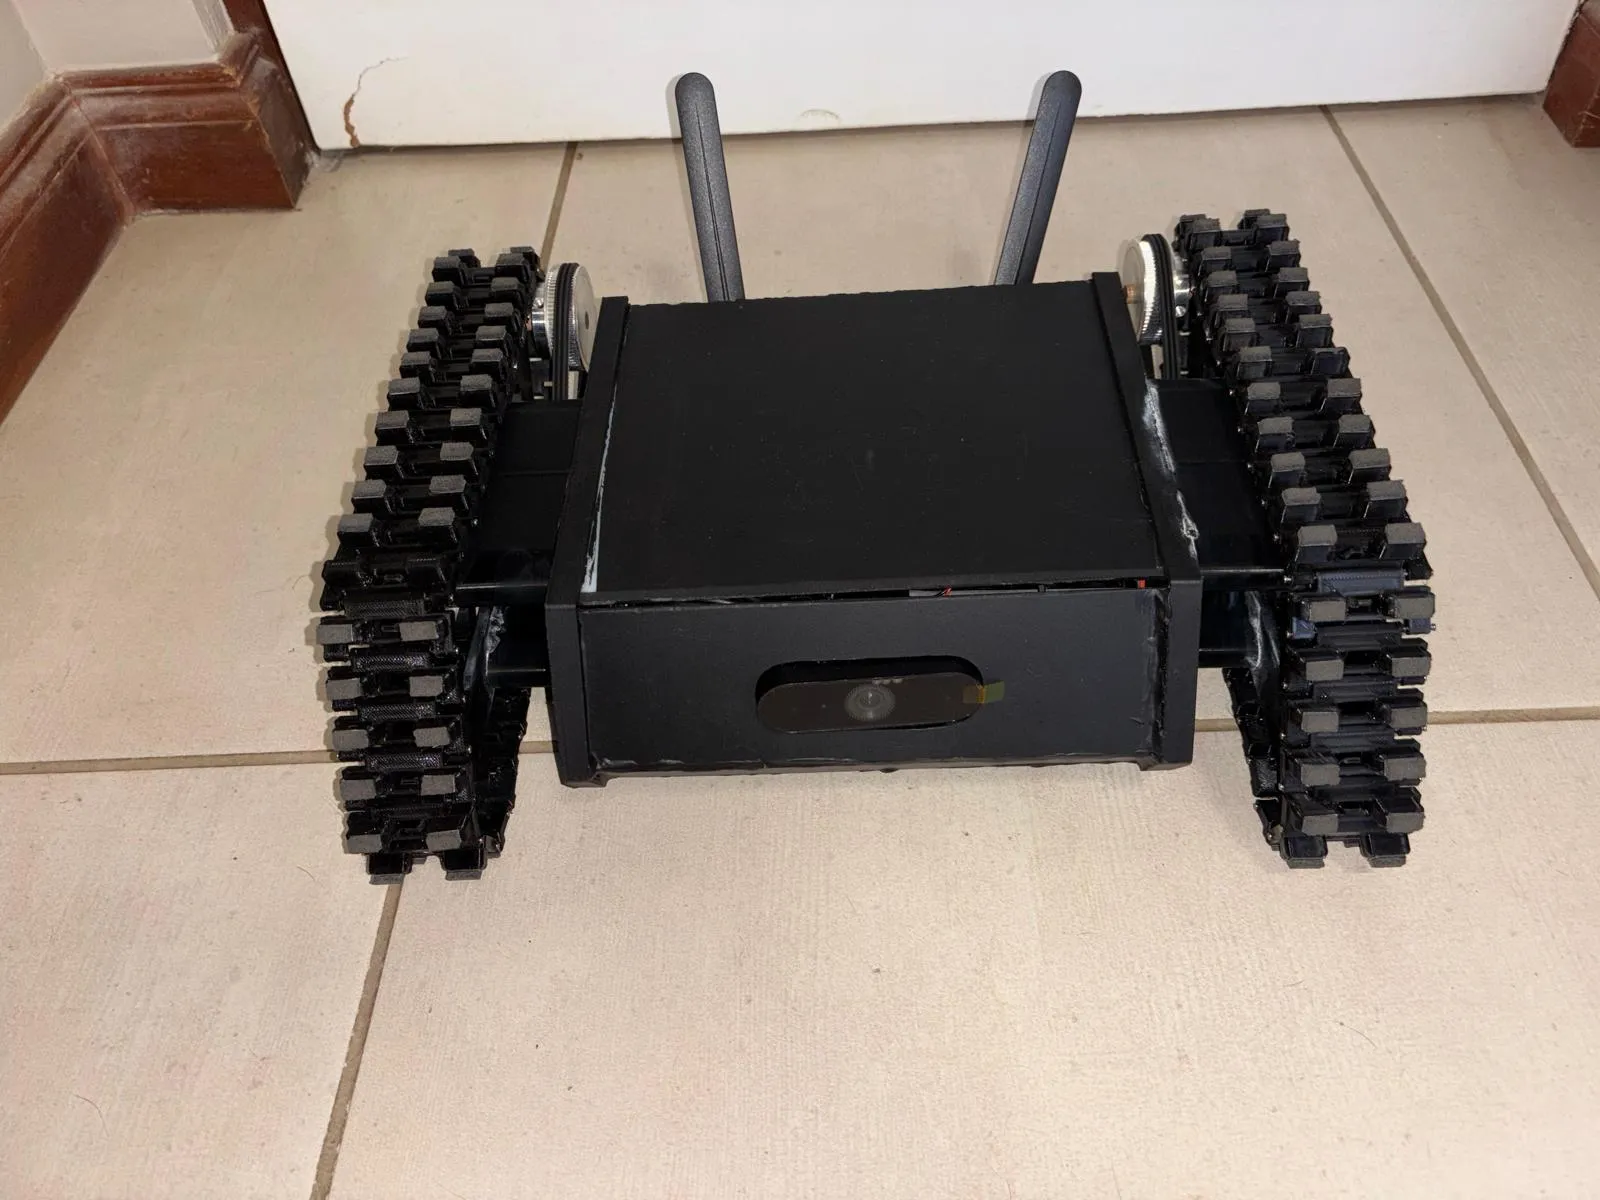
Camera
A webcam at the front is the robot's only eye. Every decision starts from its video.
Tracks
Two motor-driven tank tracks, one each side, steer the robot by running at different speeds.
Body
Houses the Raspberry Pi that runs the detection, and the electronics that drive the motors.
Antennas
The wireless link the robot uses to send an alert when it sees someone.
Fig. 3 · control loop
How it works
The robot runs the same loop for as long as it is switched on. Everything happens on the robot itself, with no cloud and no graphics card, just a Raspberry Pi the size of a credit card.
Raspberry Pi, on board
See
The camera streams live video to the Raspberry Pi.
Detect
OpenCV looks for a person in every frame.
Decide
Alert logic decides whether what it saw is worth raising.
Act
The motors move the robot, and an alert goes out.
Notes
Challenges
A Raspberry Pi has only a small fraction of a laptop's computing power, and the video never stops coming in. The detection had to be light enough to keep up, and the alert logic had to be tuned carefully so it didn't send an alert for every shadow.
A tracked robotic system integrating perception, decision-making and actuation.
- Real-time human detection and event-based alert logic running on a resource-constrained Raspberry Pi: edge deployment of a live video inference pipeline
- Sensor, motor control and communication integration, tuned to reduce false triggers